PhysAI Real2Sim2Real
Building a real2sim2real pipeline for thin shell deformable material manipulation, extending the lab's Agentic Real2Sim work.
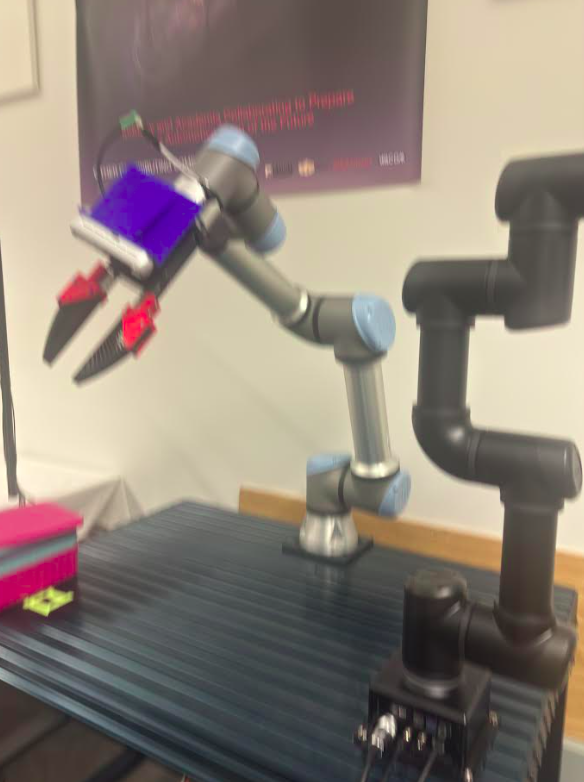
Thin shell materials like fabric, paper, and flexible components are notoriously difficult to simulate accurately. Current physics models exist but require manual parameter tuning, a slow expert-driven process that doesn't scale.
As part of the UBC PhysAI Lab under Prof. Peter Yichen Chen, I am contributing to a real2sim2real pipeline that extends the lab's Agentic Real2Sim work to thin shell materials. The goal is to identify material parameters like stiffness, damping, and deformation properties directly from video of a robot arm manipulating the material, eliminating the need for manual tuning entirely.
Once the simulation accurately reflects the real material, it can be used to train robot manipulation policies and verify them before deployment back on physical hardware, closing the loop from reality to simulation and back.
This work sits at the intersection of differentiable physics simulation, computer vision, and robot manipulation. I work with Prof. Chao Liu's robot arm and collaborate with Mengdi Wang, a postdoctoral fellow whose research spans adaptive GPU solvers and sim-to-real pipelines.